Superb quality and spec AB-Com PULSe 4K SE. Crazy offer! Only £99! FREE UK DELIVERY! 4K UHD, Enigma 2, Multiboot 4 images & more!...
Superb quality and spec AB-Com PULSe 4K Rev II Twin Satellite tuner only £149! FREE UK DELIVERY! 4K UHD, Enigma 2, SATA HDD facility, Multiboot 4 images & more!...

Testers required for OpenViX Python 3 images

Status
Not open for further replies.
Okay 157 updated packages, so I assume you have been busy.....

Configured everything from scratch as I normally do, and so far have only had 1 crash

Menu -> Information -> Devices
Displays 3 lines for each of the device types, then crashes


Meant to add, my non standard OSCAM working fine at the moment!

Which display skin are you using? What is the hardware?
 
Okay 157 updated packages, so I assume you have been busy.....

Configured everything from scratch as I normally do, and so far have only had 1 crash

Menu -> Information -> Devices
Displays 3 lines for each of the device types, then crashes


Meant to add, my non standard OSCAM working fine at the moment!

Thanks. I assume you have just the hdd and usb disks attached?
 
Okay 157 updated packages, so I assume you have been busy.....

Configured everything from scratch as I normally do, and so far have only had 1 crash

Menu -> Information -> Devices
Displays 3 lines for each of the device types, then crashes


Meant to add, my non standard OSCAM working fine at the moment!
Can you turn on debug logs (Menu/Setup/System/Logs/settings) and save to hdd
...and then try attachments as follows:-
putty: init 4 (space between)
copy About.py to /usr/lib/enigma2/python/Screens (rename existing About.py first)
copy Harddisk.py to /usr/lib/enigma2/python/Components (rename Harddisk.py first)
putty: init 6 (space between)
post results & log(s)
 

Attachments

...... deleted.
 
Last edited:
Can you turn on debug logs (Menu/Setup/System/Logs/settings) and save to hdd
...and then try attachments as follows:-
putty: init 4 (space between)
copy About.py to /usr/lib/enigma2/python/Screens (rename existing About.py first)
copy Harddisk.py to /usr/lib/enigma2/python/Components (rename Harddisk.py first)
putty: init 6 (space between)
post results & log(s)

Will be tonight before I can try this.


H/W is Gigablue UE 4K, 2TB HDD, 16GB USB
 
It just makes an xml file. Nothing more.

This change to dvbscanner.py appears to have sorted the problem, increasing SDT_TIMEOUT from 20 to 120.

Code:
from __future__ import print_function

from .. import log

import dvbreader
import datetime
import time
import os
from Components.config import config


class DvbScanner():
	TIMEOUT_SEC = 20
	SDT_TIMEOUT [COLOR="#FF0000"]= 120[/COLOR]

	VIDEO_ALLOWED_TYPES = [1, 4, 5, 17, 22, 24, 25, 27, 31, 135]
	AUDIO_ALLOWED_TYPES = [2, 10]

The only thing I did differently from yesterday (when results were very unpredictable) was to exit AutoBouquetMaker first before rerunning a scan.

There is no increase in the scan time for the 506 mux which has always worked, the 562 mux takes much longer, but does now work.

You really should start another thread as this is not a Py3 problem.

DVB standard says all sections of "SDT actual" must be transmitted at least once every 2 seconds, and, all sections of "SDT other" must be transmitted at least once every 15 seconds, so a 20 second timeout is good for any mux that complies with the standard, but obviously yours doesn't, or is broken.

Please get a debug log of the scan with extra debug activated.

It became a P3 problem because P2 works, but probably by accident rather than by design.

I'll start a new thread.

Any chance the extra debug logs could have timestamps added?
 
I wait for the image for the sf4008 octagon to do some tests. thanks
 
Can you turn on debug logs (Menu/Setup/System/Logs/settings) and save to hdd
...and then try attachments as follows:-
putty: init 4 (space between)
copy About.py to /usr/lib/enigma2/python/Screens (rename existing About.py first)
copy Harddisk.py to /usr/lib/enigma2/python/Components (rename Harddisk.py first)
putty: init 6 (space between)
post results & log(s)


Applied new files, rebooted, but crashed again.

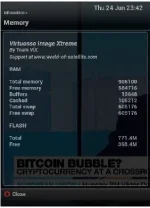
I have a 64MB swapfile configured on the usb key, and when I go into the Information Memory page, its incorrect!
Not sure where its getting the values from!
 

Attachments

Last edited:
Applied new files, rebooted, but crashed again.

I have a 64MB swapfile configured on the usb key, and when I go into the Information Memory page, its incorrect!
Not sure where its getting the values from!
Many thanks will look at the info.
However, there is no way you need a swap file on this box! system allocates one on mmcblk0p10 (eMMC partition) already 539644 kB (I guess added when Kodi was initially supported)
 
Last edited:
Applied new files, rebooted, but crashed again.

I have a 64MB swapfile configured on the usb key, and when I go into the Information Memory page, its incorrect!
Not sure where its getting the values from!
So issue was the 2TB HDD - incorrect statement (brackets error)

try new attachment (About.py)
 

Attachments

On ax61 - 5.5.13.016 I got a crash in Positioner Setup when I selected Calibrate (Yellow key).

Relevant section:

Code:
  9974.0772> 10:20:17.6616 [eInputDeviceInit] 0 190 (400) 1
<  9974.0773> 10:20:17.6617 [eRCDeviceInputDev] emit: 0
<  9974.0786> 10:20:17.6630 [InfoBarGenerics] Key: 400 (Break) KeyID='KEY_YELLOW' Binding='('YELLOW',)'.
<  9974.0788> 10:20:17.6631 [ActionMap] Keymap 'ColorActions' -> Action = 'yellow'.
<  9974.0789> 10:20:17.6632 USALS calibration
<  9974.0790> 10:20:17.6634 USALS calibration
<  9974.0792> 10:20:17.6636 Traceback (most recent call last):
<  9974.0793> 10:20:17.6636   File "/usr/lib/enigma2/python/Components/ActionMap.py", line 80, in action
<  9974.0803> 10:20:17.6646     return ActionMap.action(self, contexts, action)
<  9974.0804> 10:20:17.6648   File "/usr/lib/enigma2/python/Components/ActionMap.py", line 60, in action
<  9974.0808> 10:20:17.6651     res = self.actions[action]()
<  9974.0808> 10:20:17.6652   File "/usr/lib/enigma2/python/Plugins/SystemPlugins/PositionerSetup/plugin.py", line 703, in yellowKey
<  9974.0826> 10:20:17.6669     print>>log, (_("Site latitude") + "      : %5.1f %s") % PositionerSetup.latitude2orbital(self.sitelat)
<  9974.0827> 10:20:17.6671 TypeError: unsupported operand type(s) for >>: 'builtin_function_or_method' and 'module'. Did you mean "print(<message>, file=<output_stream>)"?
<  9974.0828> 10:20:17.6671 [ePyObject] (CallObject(<bound method NumberActionMap.action of <Components.ActionMap.NumberActionMap object at 0xafb2ebf8>>,('ColorActions', 'yellow')) failed)

Full crashlog:

fixed yesterday in Git
 

Attachments

Last edited:
Thanks @twol - I did search the thread for any reports of this issue and did look at the github commit emails, but didn't spot anything specific to PositionerSetup. I'll download the py files and re-test.
 
Thanks @twol - I did search the thread for any reports of this issue and did look at the github commit emails, but didn't spot anything specific to PositionerSetup. I'll download the py files and re-test.

don't forget to stop the box before copying over & then reboot (preferably with putty :- init 4 % then init 6)
 
Status
Not open for further replies.

OpenViX Feeds Status

Back
Top